Learning Geometry-Aware Planning Representations for Monocular Flight with Cross-Modal Supervision (GeoMonoPlan)
IEEE Robotics and Automation Letters (RA-L), Revision submitted.
Hello! Welcome to my homepage.你好!欢迎来到我的个人主页。
I am a master's student in Control Theory and Control Engineering at Tianjin University. My research focuses on learning-based planning and control, with particular interests in end-to-end motion planning, multimodal learning, and embodied intelligence.我目前就读于天津大学控制理论与控制工程专业硕士。我的研究聚焦于学习式规划与控制,尤其关注端到端运动规划、多模态学习与具身智能。
My previous work has mainly centered on end-to-end planning for agile quadrotors, including monocular and omnidirectional visual planning, with lightweight onboard deployment and real-world flight validation. More recently, I started exploring vision-language-action models for Embodied AI.我此前的工作主要围绕敏捷四旋翼的端到端规划展开,包括单目与全向视觉规划,并完成轻量化板端部署与实机飞行验证。近期,我开始探索面向具身智能的视觉-语言-动作模型。
🔬 Research interests: aerial robotics, end-to-end planning, vision-language-action models, multimodal learning, embodied intelligence, sim-to-real transfer, and efficient robotic inference.🔬 研究方向:空中机器人、端到端规划、视觉-语言-动作模型、多模态学习、具身智能、仿真到实机迁移与高效机器人推理。
👋 If you are interested in my work, please feel free to reach out for discussions or collaborations via 3021001416@tju.edu.cn or GitHub.👋 如果你对我的工作感兴趣,欢迎通过 3021001416@tju.edu.cn 或 GitHub 与我交流或探讨合作。
IEEE Robotics and Automation Letters (RA-L), Revision submitted.
IEEE Transactions on Automation Science and Engineering (T-ASE), Revision submitted.
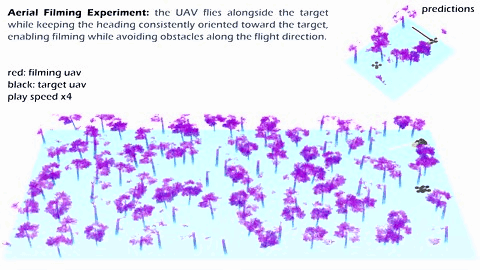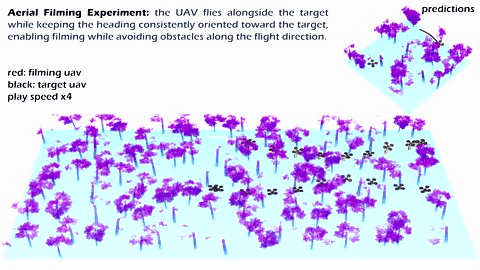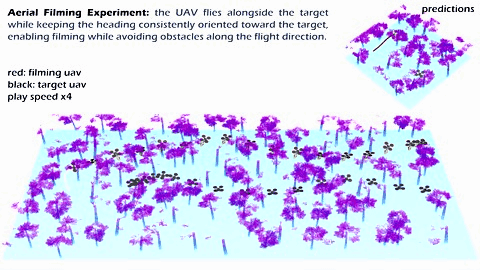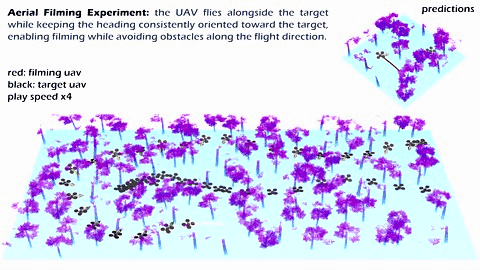
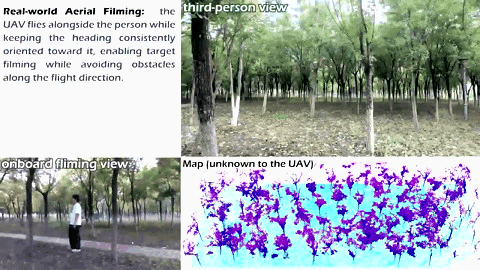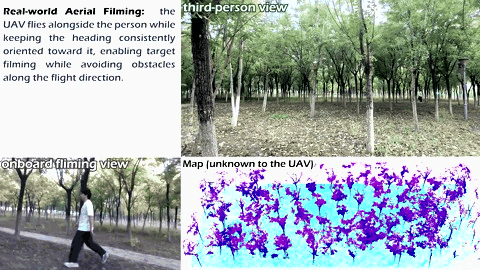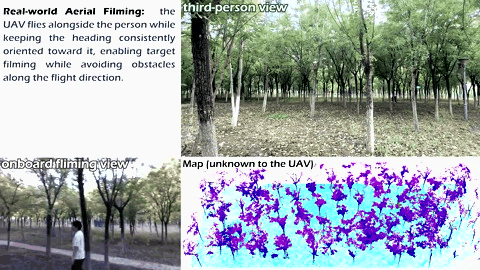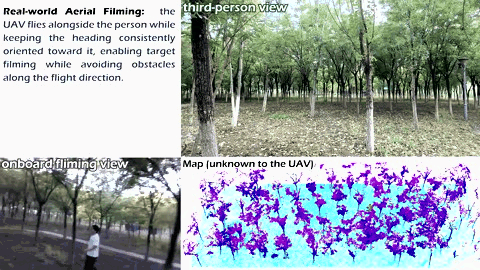
IEEE Transactions on Robotics (T-RO), 2026. 🎉 Accepted.
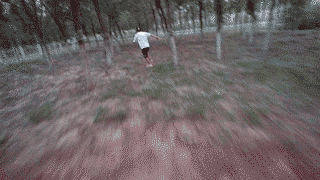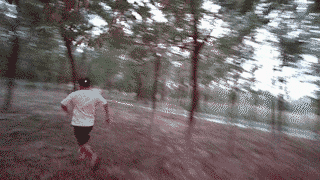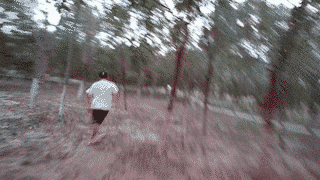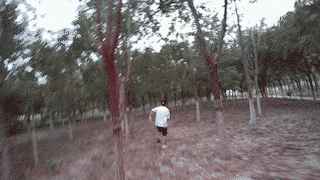
IEEE Transactions on Emerging Topics in Computational Intelligence (TETCI), under review.
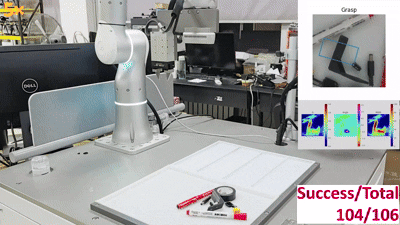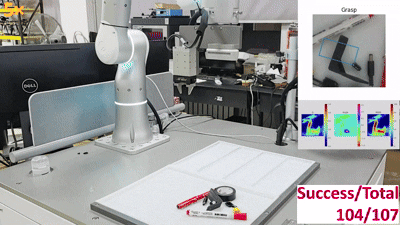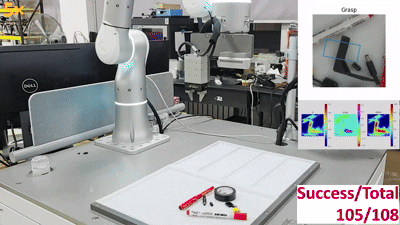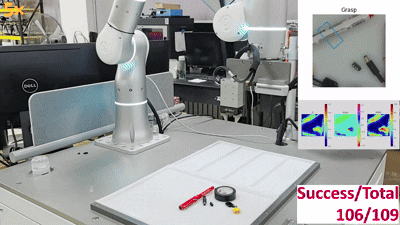
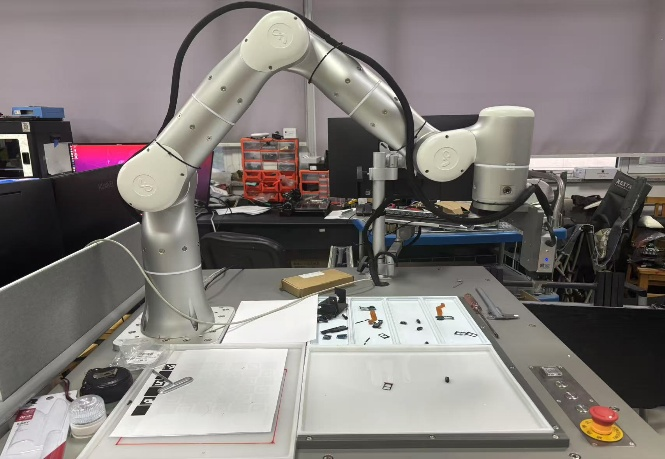
Exploring language instruction following and the use of geometric information in robotic grasping. Fine-tuning NVIDIA GR00T N1.7 in simulation, with a focus on grasp-action generation, and investigating depth information for grasping. Preparing paraphrased and counterfactual instruction data based on public datasets from LIBERO, RoboTwin, and SimpleEnv, along with semantic segmentation, grasp-stage, and grasp-quality labels for auxiliary supervision.探索机器人抓取任务中的语言指令遵循和几何信息利用,基于 NVIDIA GR00T N1.7 开展仿真微调,聚焦抓取动作生成,并研究深度信息在抓取中的作用。基于 LIBERO、RoboTwin 和 SimpleEnv 的公开数据集整理同义表达与反事实指令数据,并构建语义分割、抓取阶段和抓取质量标签,用于辅助监督。
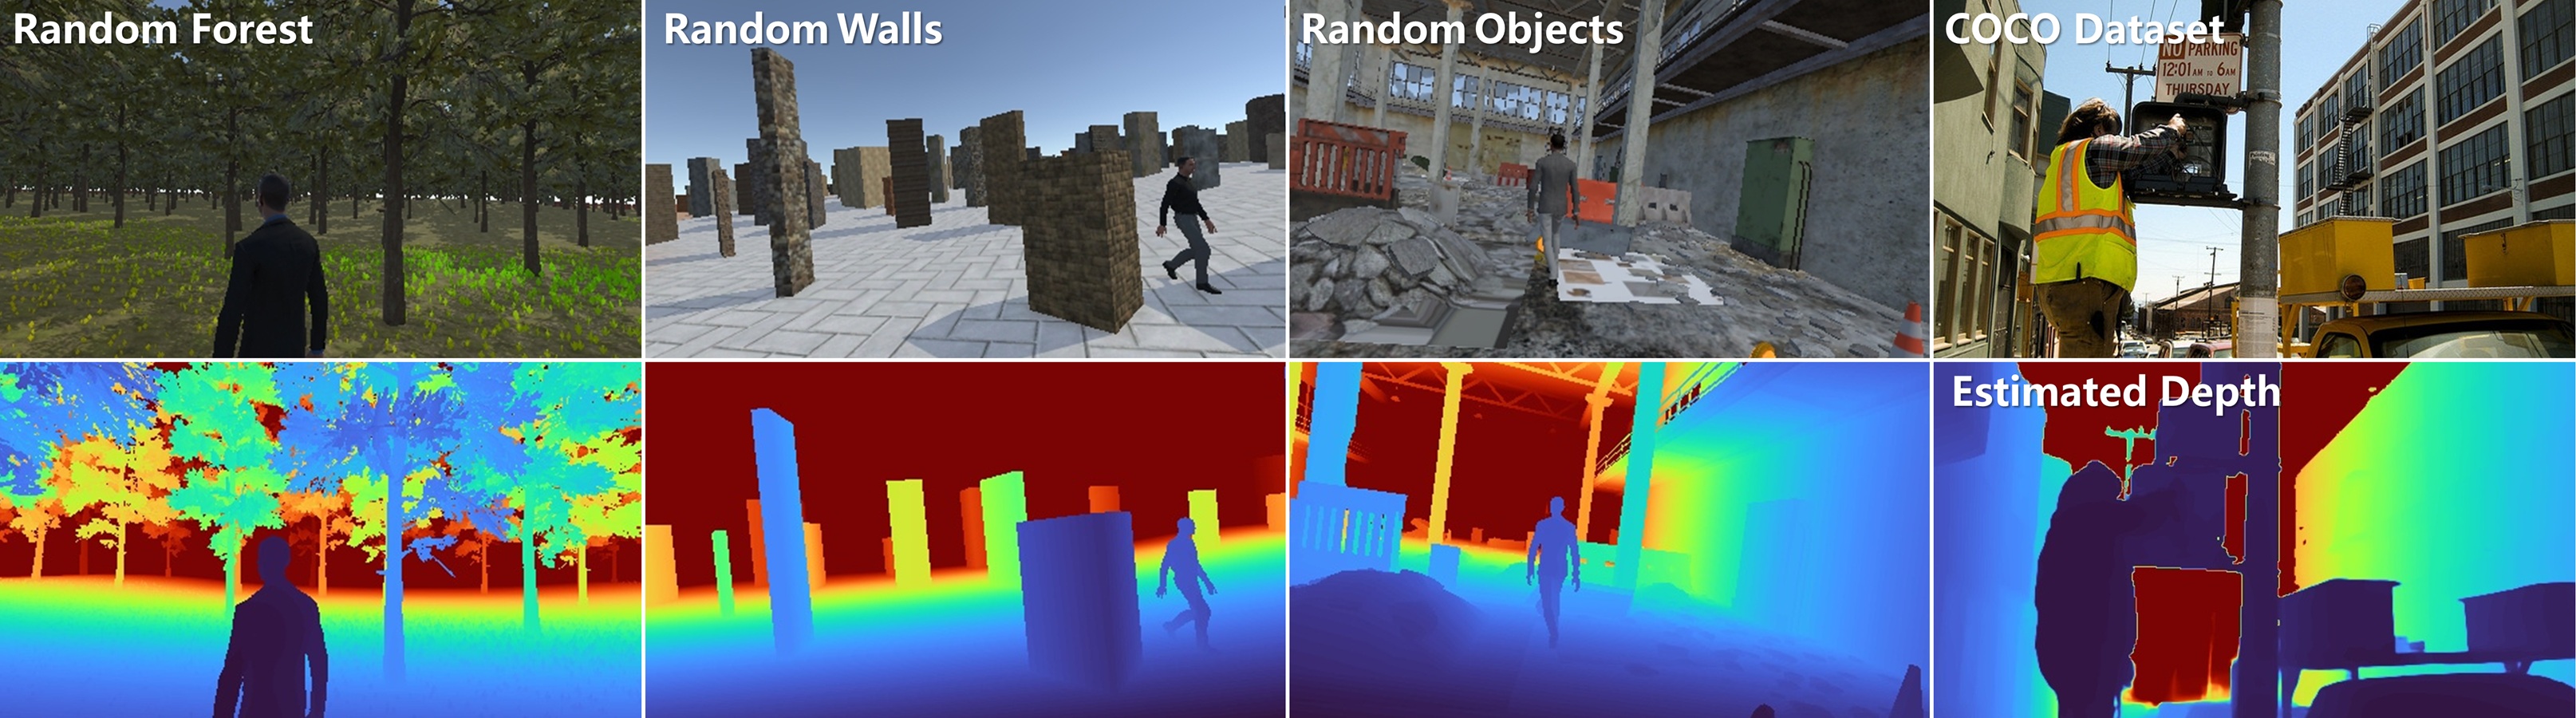
To address the inherent scale ambiguity and limited geometric cues of monocular vision, developed a geometry-aware end-to-end planner that combines consecutive monocular frames with camera pose and learns from a privileged depth expert through cross-modal supervision. Built a 3DGS-based sim-to-real pipeline and achieved 8 m/s in simulation and 6.5 m/s in real-world flight.针对单目视觉固有的尺度模糊与几何线索不足问题,研发结合连续单目图像与相机位姿的几何感知端到端规划器,并利用特权深度专家进行跨模态监督。搭建基于 3DGS 的 Sim-to-Real 流程,仿真与实机最高飞行速度分别达到 8 m/s 和 6.5 m/s。
Developed a lightweight end-to-end planner that fuses a single depth image with UAV state to predict terminal states and generate polynomial trajectories online. Optimized and quantized the model with RKNN, achieving approximately 20 ms inference latency on RK3588; the complete onboard system was delivered and passed acceptance testing.研发融合单帧深度图与无人机状态的轻量化端到端规划器,预测终点状态并在线生成多项式轨迹。基于 RKNN 完成模型优化与量化,在 RK3588 上实现约 20 ms 推理延迟;整套机载系统完成交付并通过验收。
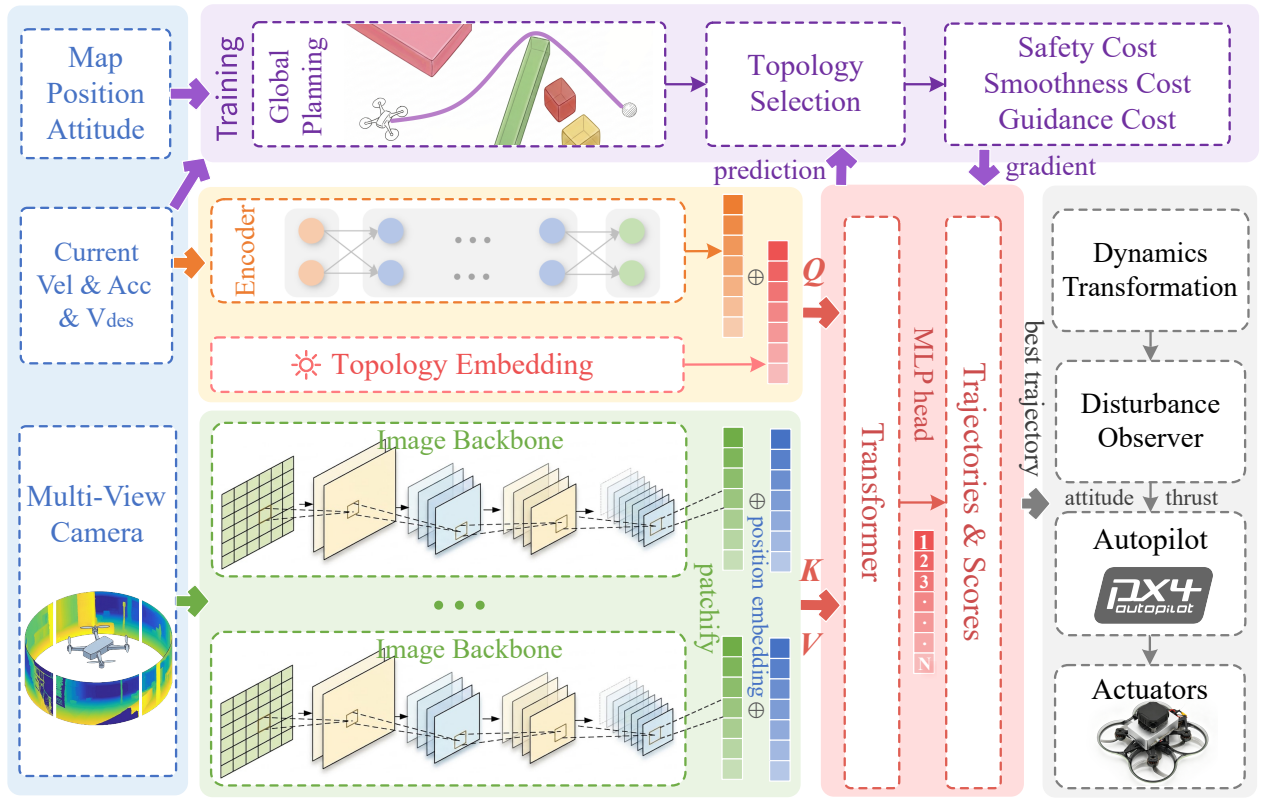
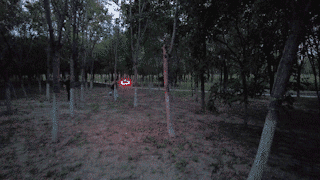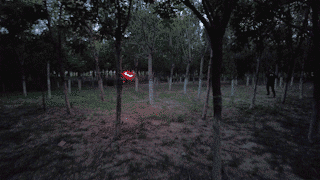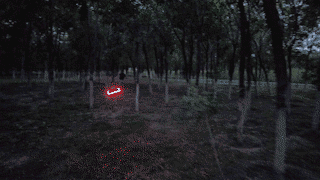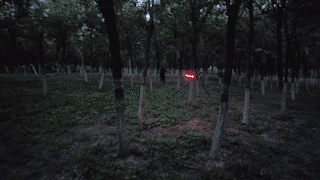
Developed an omnidirectional planner that fuses multi-view depth, UAV state, and target information, with planning-expert guidance for anticipatory obstacle avoidance. Built the quadrotor platform and validated the system at approximately 6 m/s in simulation and 3 m/s in real-world forest environments.研发融合多视角深度、无人机状态与目标信息的全向规划器,并利用规划专家引导实现前瞻式避障。完成四旋翼平台搭建,在仿真和真实森林环境中分别以约 6 m/s 和 3 m/s 完成验证。
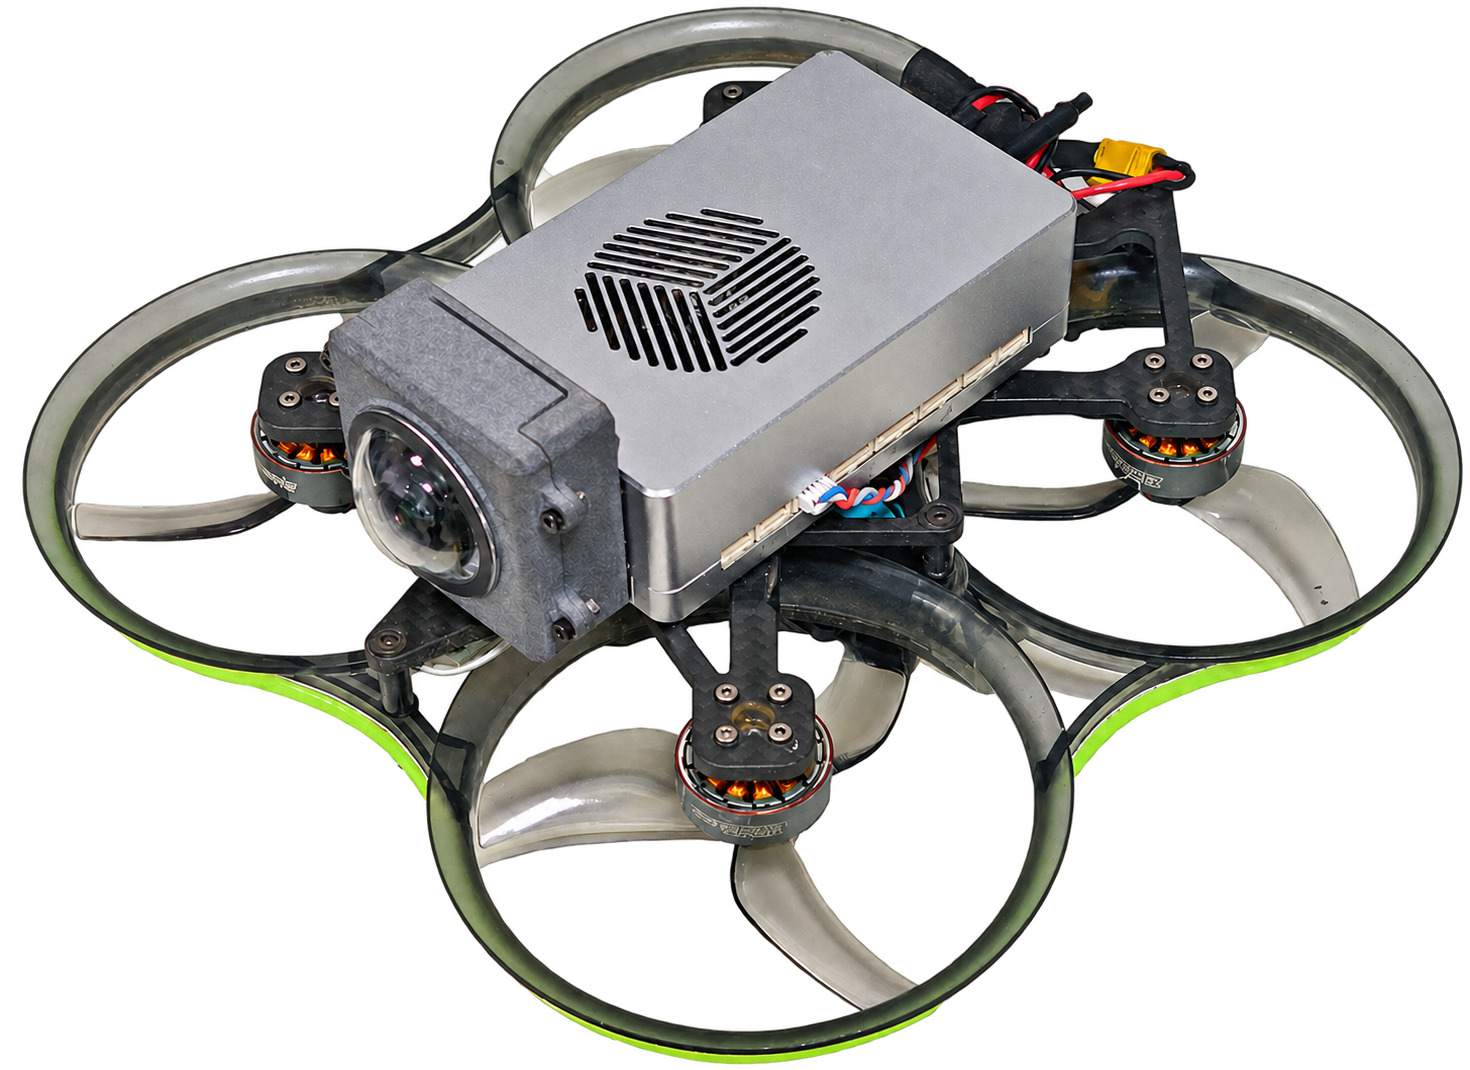
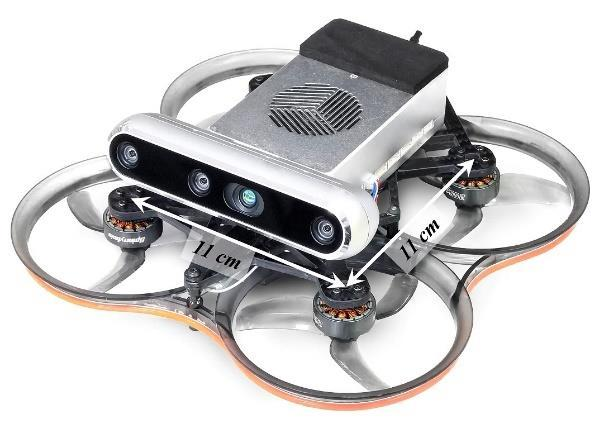
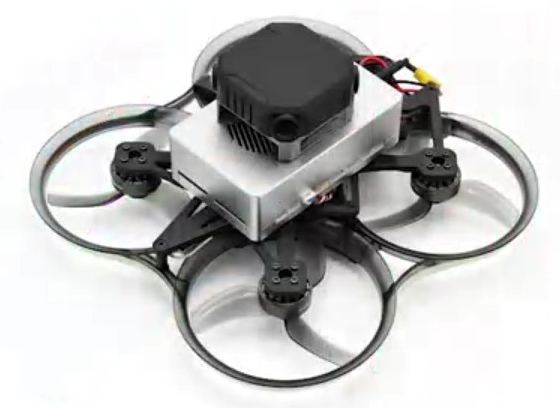
Led the ongoing design and development of the compact quadrotor platform currently used by the lab for agile-flight research. Carbon-fiber plates, 3D-printed parts, and assembly models are open-sourced in AeroForge, covering compact quadrotors with depth, monocular, and omnidirectional camera configurations.自本科阶段起持续负责实验室现用紧凑型四旋翼平台的设计与研发,用于敏捷飞行研究。碳板、打印件与总装模型已在 AeroForge 仓库开源,涵盖深度、单目及全向相机配置的紧凑型四旋翼平台。
Tianjin University天津大学
Tianjin University · GPA 3.7/4.0 · Weighted average 88.2/100天津大学 · GPA 3.7/4.0 · 加权成绩 88.2/100
Technical skills: PyTorch, Transformers, ResNet, ROS, Python, Linux, Git, ONNX, TensorRT, RKNN, multi-view fusion, and sim-to-real deployment.技术栈:PyTorch、Transformer、ResNet、ROS、Python、Linux、Git、ONNX、TensorRT、RKNN、多视角融合与仿真到实机部署。